 Artisan
Gloves for
robot training.
Show your AI what work feels like.
Capture pressure, texture, movement and video.
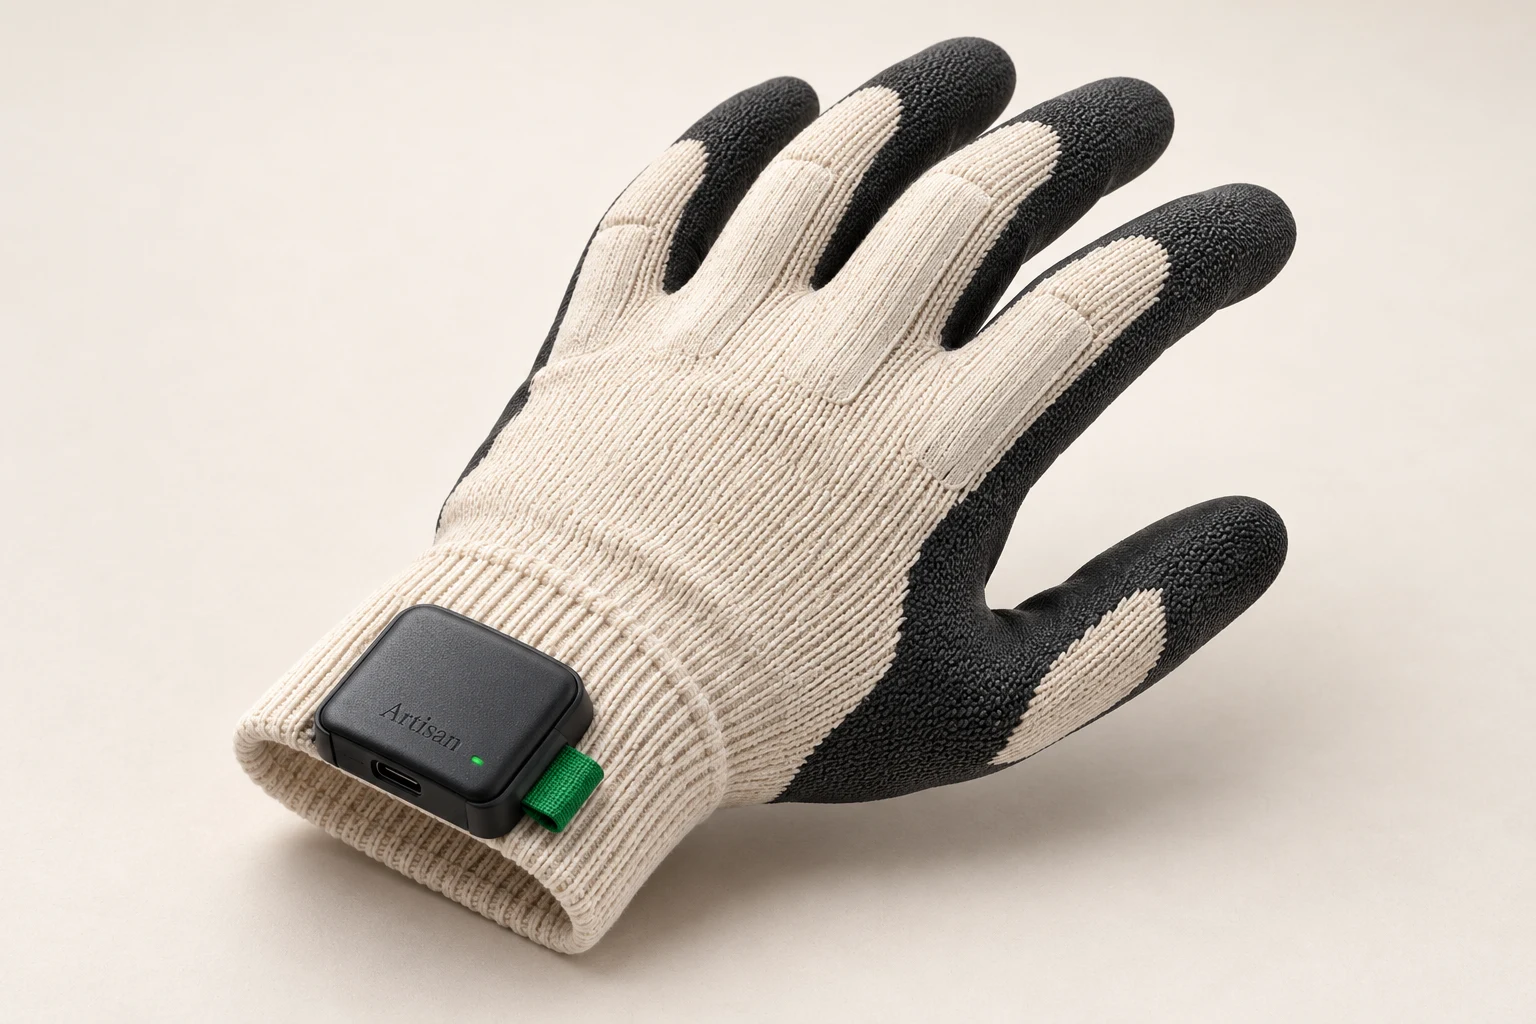
Human demonstrations.
Data for your robot.
Record the details of skilled work, from the pressure of a grip to the texture under a fingertip. Bring what you feel into the demonstrations your AI learns from.
Meet your robot companionPressure. Texture.
At your fingertips.
See where the fingers touch.
Follow the vibrations as they move across a surface.
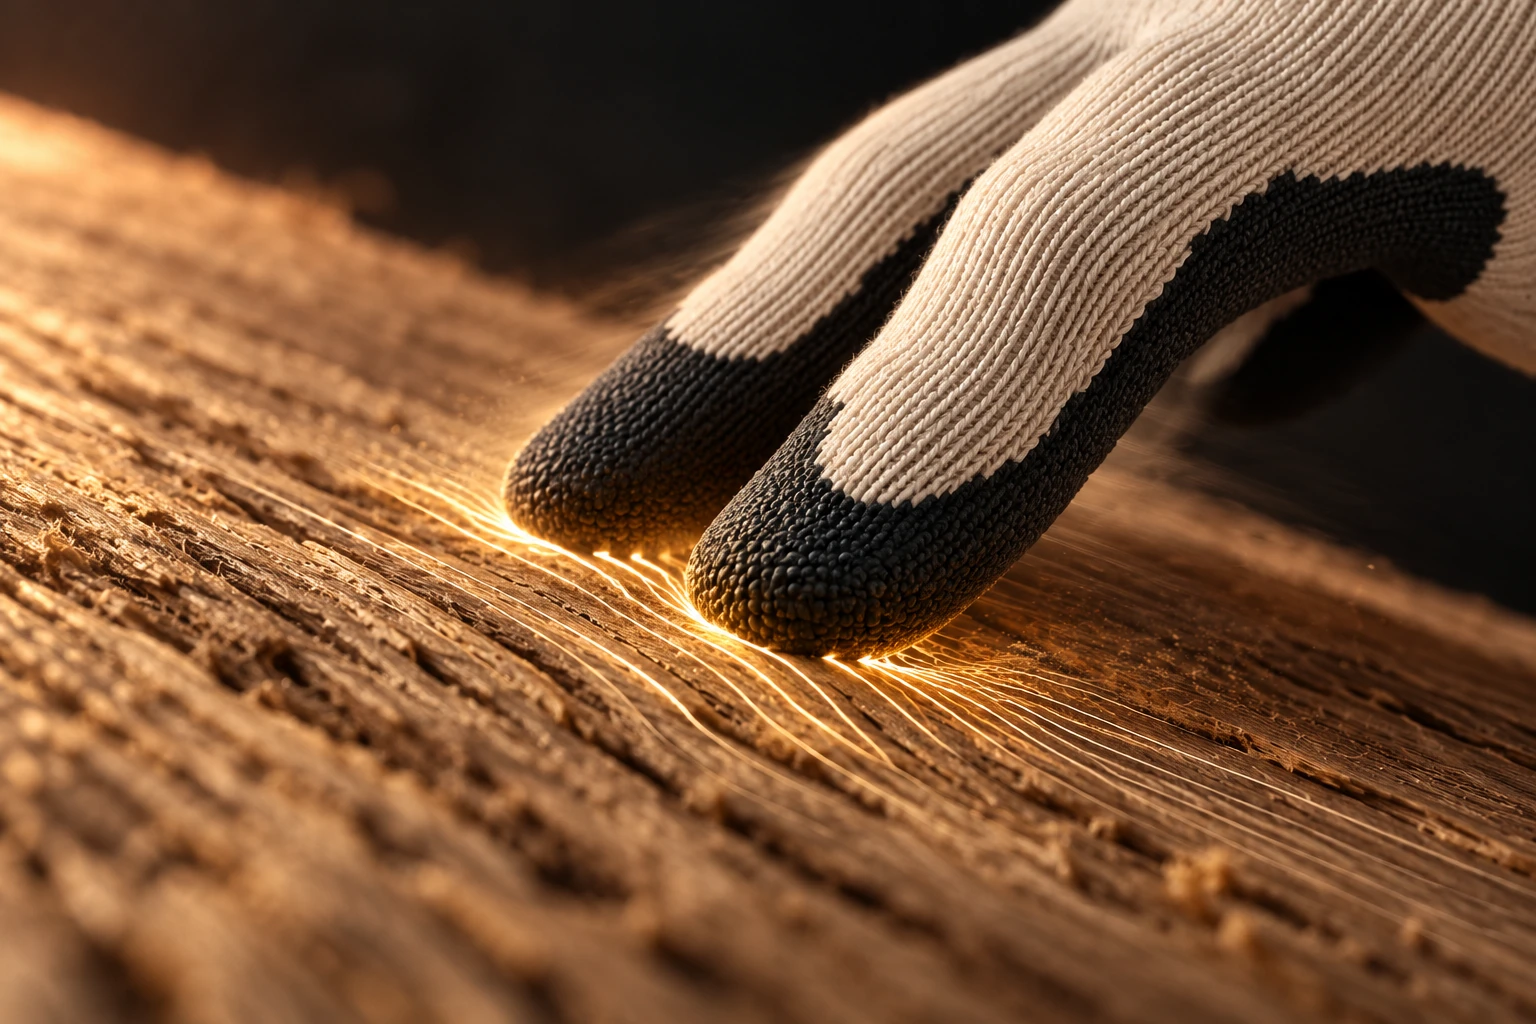
A surface in the signal.
Touch, move, lift.
Keep the whole gesture together.
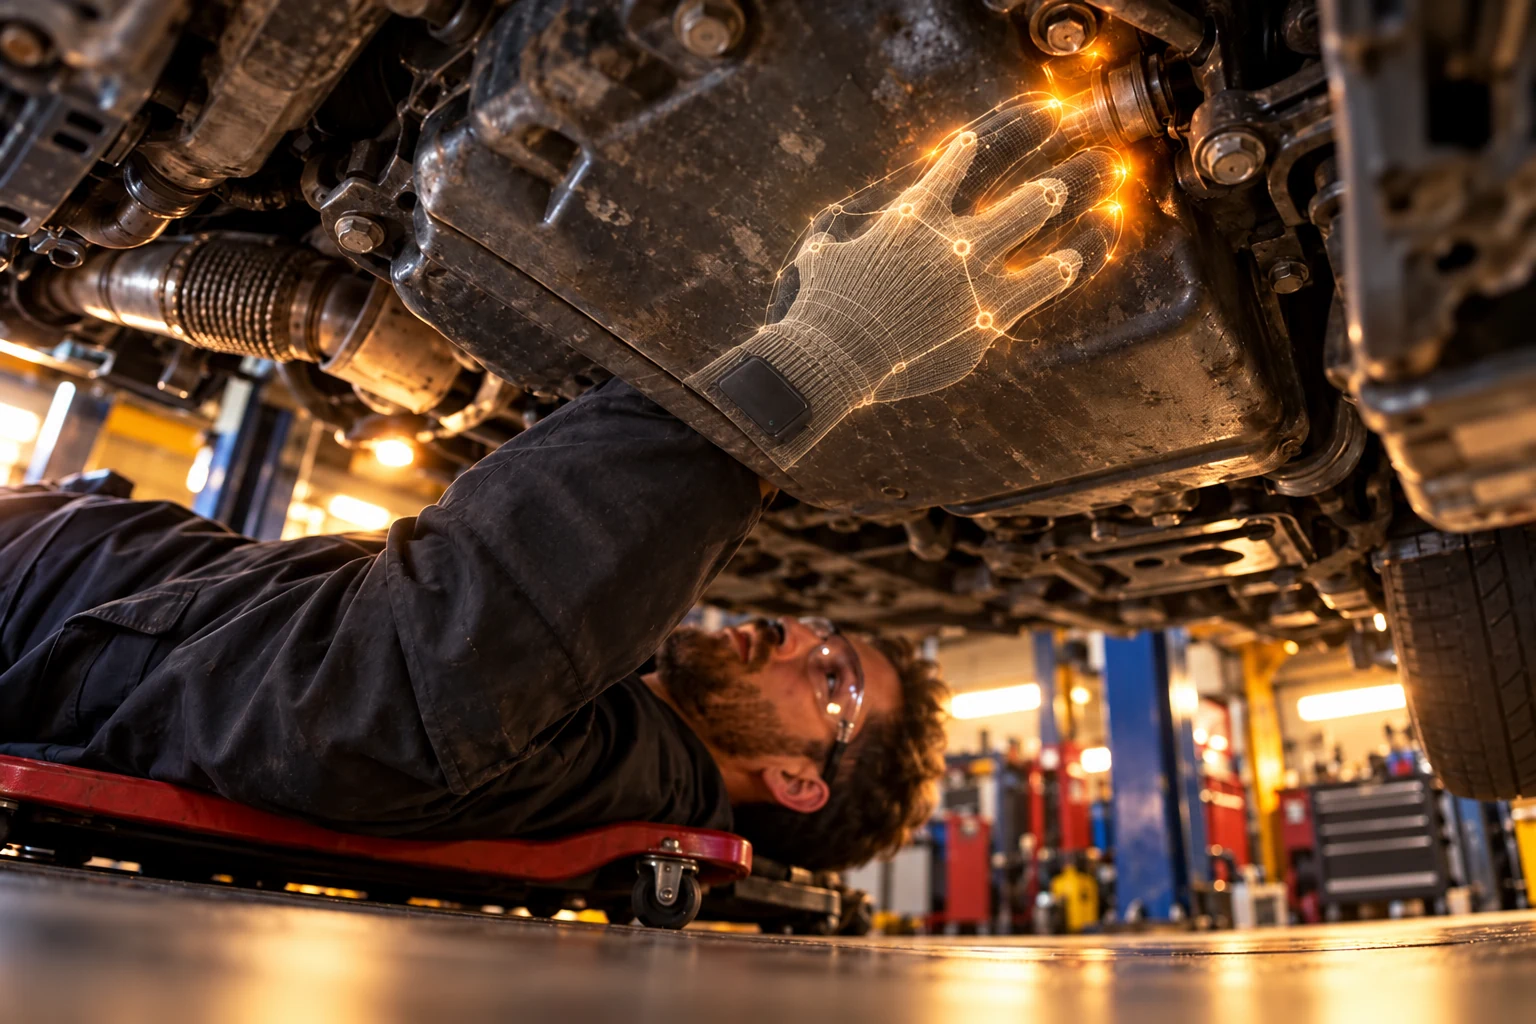
Hand positioning.
Even out of sight.
The movement. The grip. The point of contact.
A continuous view of the hand as it reaches out of sight.
A camera
with a hand’s-eye view.
A close view of the mechanism you’re working on.
Recorded alongside each touch and movement.
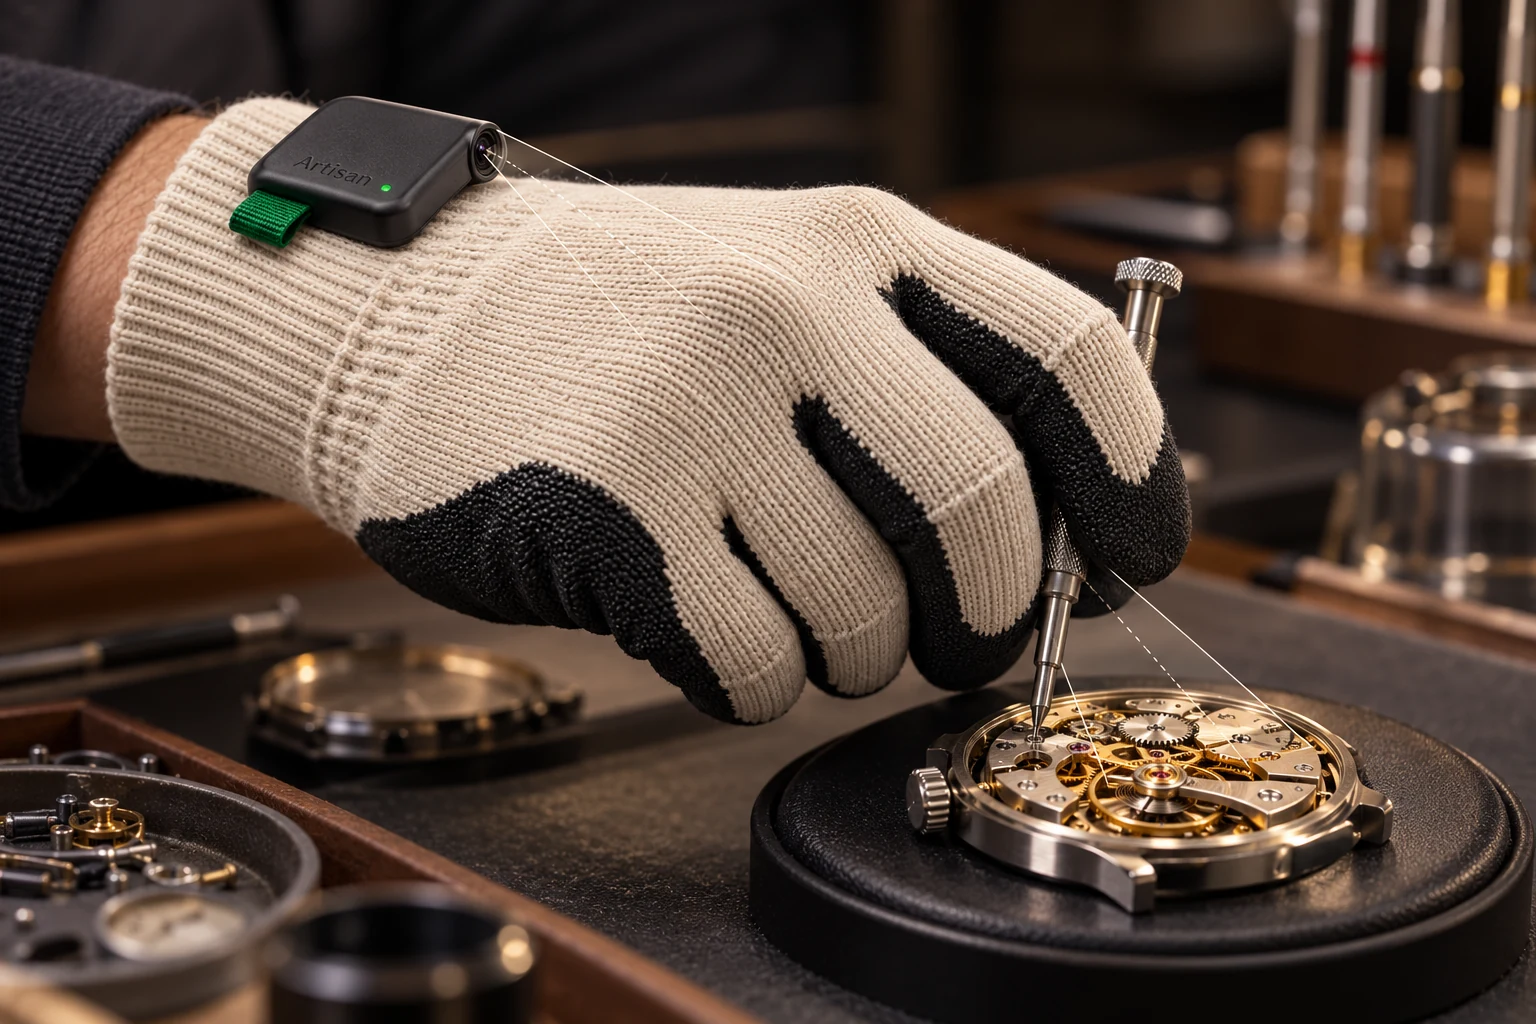
One glove.
A record of the work.
Local sensing
Pressure and vibration at 20 planned locations.
One button
Wake, connect and power down from the cuff.
USB-C charging
A familiar connection at the wrist.
Your data.
You own it.
See how your hand gets steadier.
Keep your recordings. Choose which ones earn for you.
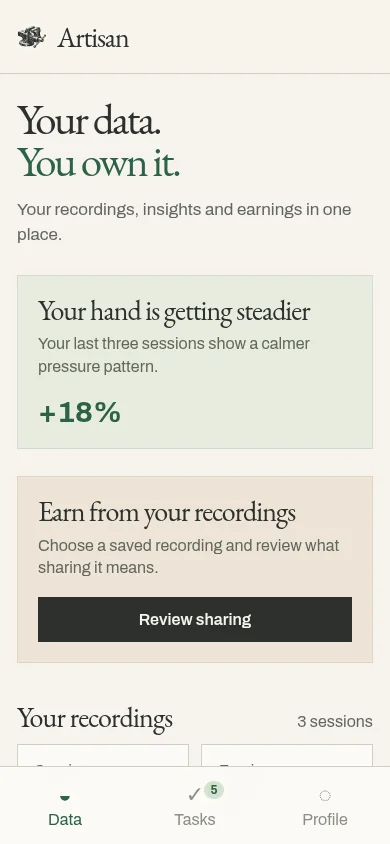
Coming soon
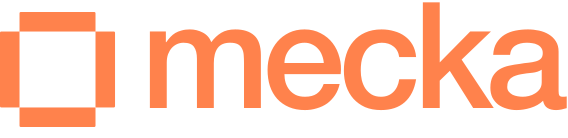
Paid tasks.
For robot training.
Our planned Mecka integration brings guided data-collection tasks to the app. Complete a task and get paid for the demonstrations you choose to share.
Data for robot-learning teams.

Planned exports for Physical Intelligence’s openpi and RLDS bring your demonstrations into open robot-learning workflows.
About this design
Product imagery illustrates the experience in development. The pose overlays, surface contours and camera view explain the concept. Tracking accuracy, roughness measurement, final cuff dimensions and runtime remain part of hardware validation.